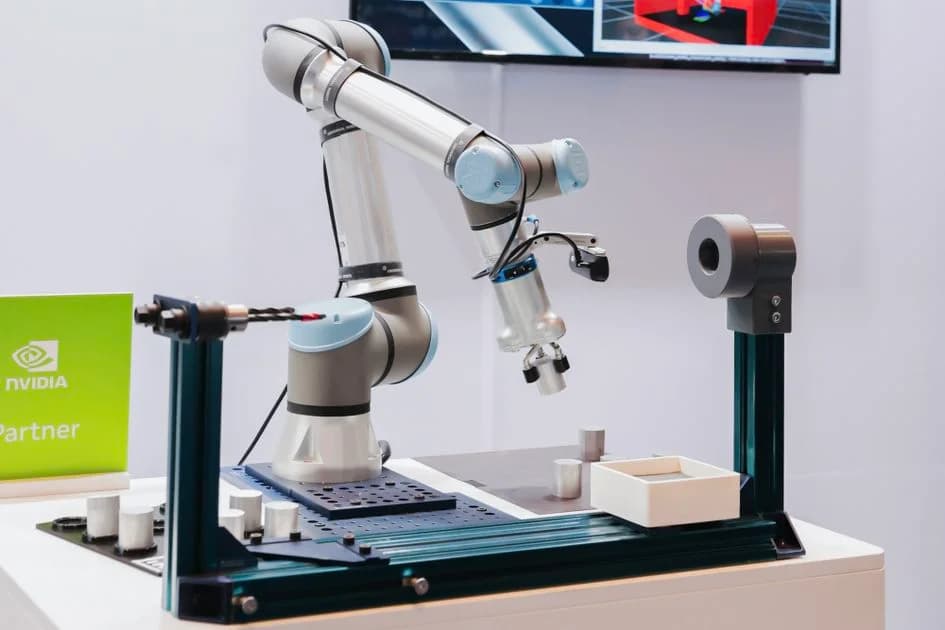
In robotics, few technologies have had a greater impact on innovation than ROS (Robot Operating System). What began as an open-source framework for robotics research has become the common language of modern robotics development, powering everything from autonomous mobile robots to AI-driven manipulation systems.
Yet many developers discover that building a robot application and deploying it reliably in the real world are two very different challenges.
This is where the combination of ROS and Universal Robots creates a powerful foundation.
ROS provides the software ecosystem developers know and trust, while UR offers the industrial grade hardware, interfaces, safety systems and developer tools that help transform robotic concepts into deployable automation solutions.
Why ROS has become the standard robotics platform
ROS is not an operating system in the traditional sense. It is an open-source robotics middleware that provides a collection of libraries, communication tools, development frameworks, and reusable software components that accelerate robotics development.
The reason ROS has become so widely adopted is simple:
Faster Development
Developers don’t need to build communication frameworks, motion planning tools, visualization software, or perception pipelines from scratch. ROS provides many of these building blocks out of the box.
Modular Architecture
ROS applications are built using independent nodes that can be developed, tested, and updated separately. This modular approach promotes code reuse and simplifies complex system integration.
Rich Ecosystem
ROS offers access to thousands of open-source packages covering navigation, manipulation, machine vision, perception, AI integration, simulation, and motion planning.
Strong Community
A global community of researchers, developers, startups, and industrial companies continuously contributes frameworks, tools, and best practices.
For developers, this means more time spent creating differentiated solutions and less time rebuilding infrastructure.
The challenge, ROS alone doesn’t solve deployment
While ROS dramatically accelerates development, many robotics projects encounter the same obstacles when moving from prototype to production.
A system that performs well in simulation often behaves differently on physical hardware. Integrating sensors, robot controllers, safety systems, and real-time motion can become a significant engineering effort. Many teams spend more time developing custom interfaces and maintaining drivers than improving their actual application.
In AI robotics applications, this challenge becomes even more apparent. The bottleneck is rarely the AI model itself. The challenge is connecting perception, planning, and decision-making systems to a robot platform that can execute tasks safely, reliably, and repeatedly.
Why Universal Robots is an ideal platform for ROS development
Universal Robots has invested heavily in supporting ROS and ROS 2, making it easier for developers to move from experimentation to deployment.
Official ROS and ROS 2 Support
Universal Robots provides and maintains official ROS and ROS 2 drivers, helping developers integrate quickly without relying on unsupported third-party solutions.
This gives developers access to:
- Robot control and monitoring
Robot control and monitoring
- Motion planning through MoveIt
Motion planning through MoveIt
- Visualization tools
Visualization tools
- Simulation workflows
Simulation workflows
- External application integration
External application integration
Built for Sim-to-Real Development
Universal Robots supports common ROS development workflows with URSim, robot descriptions, simulation assets, calibration data, and ROS support This helps reduce the gap between simulation and real-world deployment.
Instead of rebuilding applications for deployment, developers can validate algorithms in simulation and transition them to production hardware more efficiently.
Open Interfaces for Advanced Robotics
Modern robotic applications increasingly combine AI, perception, force control, vision systems, and external compute platforms.
Universal Robots provides open interfaces such as:
- RTDE
- URScript
- ROS 2 communication in URScript (PolyscopeX)
- XML-RPC
- TCP/IP communication
- C++ Client library https://github.com/UniversalRobots/Universal_Robots_Client_Library
- ROS / ROS 2 Driver https://github.com/UniversalRobots/Universal_Robots_ROS2_Driver
These interfaces allow developers to integrate external software, sensors, GPUs, and AI frameworks while maintaining deterministic robot control.
Real-Time Data for AI and Advanced Automation
AI models depend on high-quality data.
Universal Robots provides access to robot state information, force data, joint positions, telemetry, and kinematic information that developers can use for:
- Learning systems
- Force-sensitive assembly
- Vision-guided robotics
- Autonomous manipulation
- Physical AI applications
Industrial Reliability and Safety
This is where many robotics platforms struggle.
Research platforms can demonstrate innovative concepts, but deploying robots in production environments requires reliable execution, certified safety, and predictable behavior.
Universal Robots combines ROS flexibility with industrial-grade reliability and TÜV-certified safety architecture, helping developers deploy robotic applications in real manufacturing environments.
Accelerating AI Robotics with NVIDIA Isaac ROS
One of the clearest examples of this in practice is Universal Robots’ work with NVIDIA Isaac ROS, a set of GPU-accelerated packages for perception and AI on ROS 2. For AI-driven applications, the hard part is rarely the model. It is connecting perception, planning, and decision-making to a robot that can act on them safely and repeatedly. Isaac ROS gives Universal Robots validated building blocks for that work, so engineering effort goes into the application itself rather than the perception and motion planning layers beneath it.
Packages such as FoundationStereo, FoundationPose, and cuMotion, already validated by NVIDIA on Jetson, underpin projects where the robot has to handle variability in its workspace. Because these components are proven on Jetson hardware, teams start from a working foundation rather than assembling perception and motion planning from scratch.
Universal Robots’ AI Accelerator SDK is built on Isaac ROS. Combined with ROS 2 communication in the UR controller, it bridges advanced perception directly into URScript at runtime. A UR program can act on a pose estimate or a planned trajectory as it runs, and an integrator does not have to work in ROS 2 to make use of it.
The pipeline runs on a single Jetson device at the edge of the cell over standard ROS 2 interfaces, which keeps it supportable by Universal Robots’ own teams and partners once deployed. It also lets an application accommodate parts that are not presented in a fixed position, removing fixturing that a customer would otherwise design and maintain.
As Andrew Pether, Head of AI Partnerships, Teradyne Robotics AI Group, recently explained “Isaac ROS lets us bring perception and AI-based solutions to market far faster than building from scratch. Components like FoundationStereo, FoundationPose, and cuMotion, already validated by NVIDIA on Jetson, handle the variability of a real robot workspace, so our engineering effort goes into the application itself rather than the perception and motion planning layers beneath it.”
The Future of Robotics Is Open
The robotics industry is moving toward increasingly intelligent, connected, and AI-driven systems. ROS has become the development standard that enables innovation across this ecosystem.
Universal Robots complements that ecosystem with an open platform, official ROS support, industrial reliability, and deployment-ready automation technology. The result is a development platform that allows teams to spend less time building infrastructure and more time creating robotic applications that deliver real value.
Whether you’re developing advanced manipulation, AI-powered robotics, vision-guided automation, or next-generation industrial systems, the combination of ROS and Universal Robots provides a scalable path from concept to production.