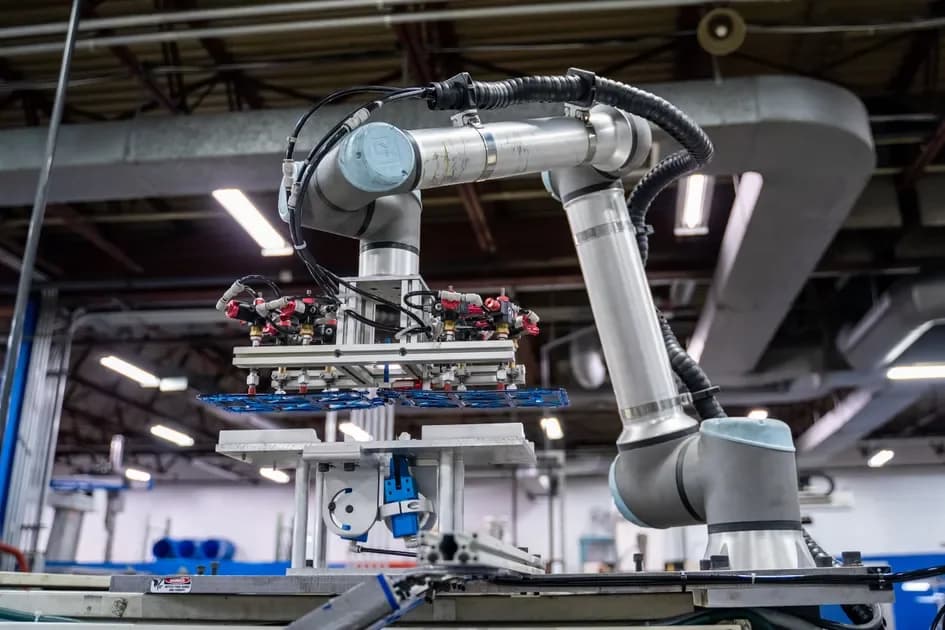
The Engineering Behind the Curve
Producing these curves is hard work. Behind every one of them is the internal logic that governs how the arm moves, and that logic has to be calculated, tuned, and proven before anything can be published.
To promise a payload at a given offset, you have to be able to predict the behavior of several parts of the robot at once. That means knowing:
- Gravity torque in every joint configuration, not one representative pose
- Friction that changes with velocity, with load, and with joint temperature, so the torque lost to it is never a fixed figure.
- Heat, because the torque a joint delivers for a short period is not the torque it can deliver across an eight-hour shift
- Structural deflection under an offset load, which under acceleration is what makes an arm oscillate and forces its limits down
- Stopping distance, since a collaborative arm must come to rest within a bounded distance from any speed, at any offset
Combining them is harder still, because they interact. Deflection changes with load, friction changes with the heat that load generates, and stopping distance depends on both.
Each has to be modelled, and the curve is where all of those models meet. It is only as good as the weakest model feeding it. This is why it has taken decades of tuning, optimizing, and developing the algorithms that do exactly this. It is why two robots, built from comparable structures, can carry their rated payload to very different offsets.
Flying Too Close to the Curve
The one thing the headline number does not tell you may be the most consequential. A payload figure can be specified for the worst case, with the least favorable combination of poses, at full speed, in the most demanding orientation. Or it can be specified for the best case, with perfect wrist orientation, reduced acceleration, and limited duty cycles. Both approaches produce a curve, but the behavior changes drastically once the robot is deployed in a real application.
A worst-case figure is a floor. It shows how the arm will perform during the most demanding application. A best-case figure is a ceiling that the arm can only reach under ideal conditions, often not reflecting reality.
Universal Robots specifies to the worst case because our robots are production equipment, built for real deployments in industrial settings. A curve that only holds in ideal conditions has not removed risk. It has transferred it to the customer.
For a buyer, the practical consequence is that two spec sheets showing the same number can mean opposite things. One is what you can count on. The other is what you might achieve. Nothing on the front page distinguishes them, only the curve and the conditions printed beside it.
Headroom is what keeps those two from diverging. Understanding the arm precisely is not, in the end, about publishing a bigger number. It is about publishing one that holds.
Before you specify your next robot, check the manual for the CoG curve. Request it alongside the rated payload, and check the conditions printed beside it. Add up everything that will sit past the flange, including the payload, and work out where the combined center of gravity actually falls. Then confirm that the point sits inside the curve, with room for the tooling you will add later.